Skip to content

Emergency Stop ​

WARNING

Always keep the emergency stop button accessible during operation. In any situation where the robot poses a risk to people or property, press the emergency stop button immediately.

E-STOP in the app ​

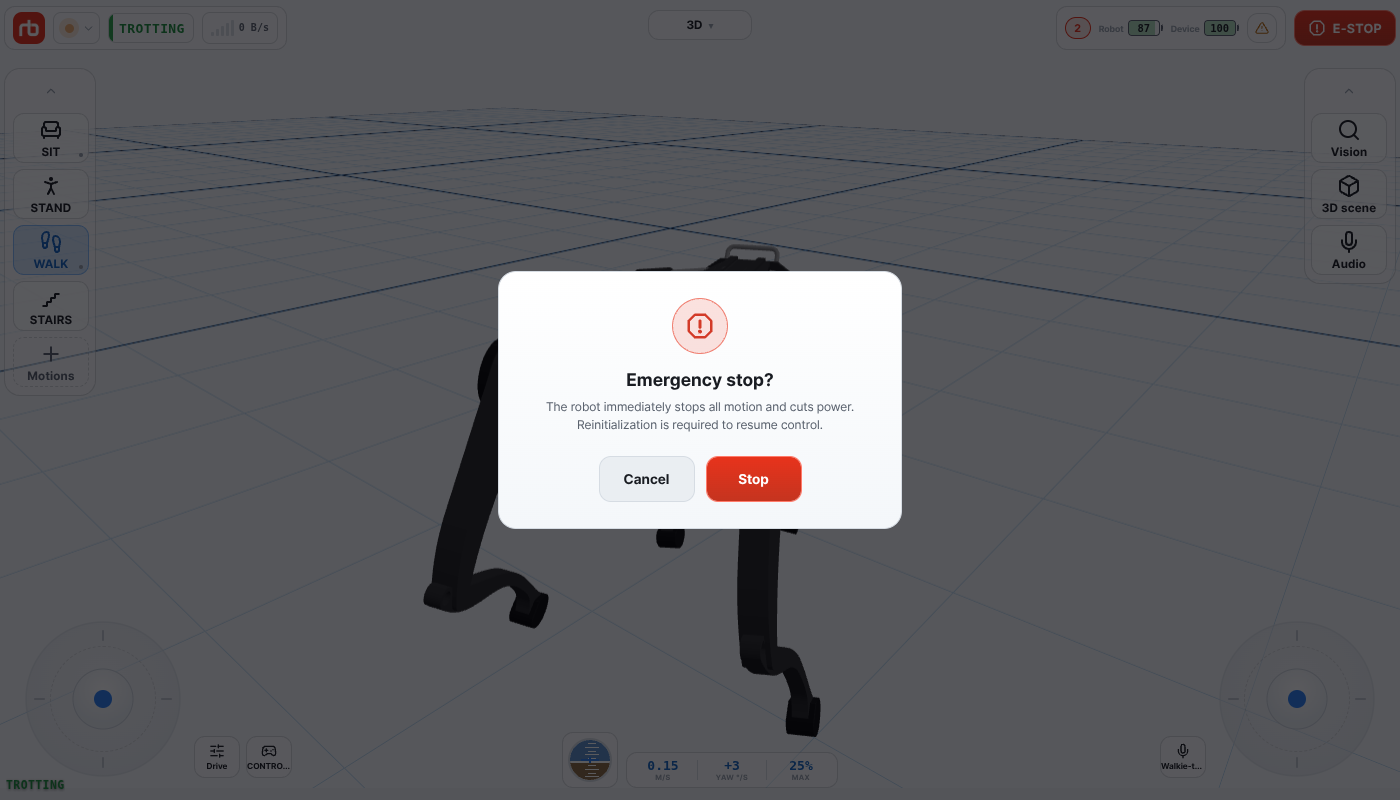
E-STOP confirmation

The red E-STOP button sits at the right of the top bar on the control home. On the other screens it sits at the right of the header, whenever a robot is connected or is reconnecting after a dropped link — it still works for 8 seconds after the drop. Pressing it opens the confirmation Emergency stop?:

The robot immediately stops all motion and cuts power. Reinitialization is required to resume control.

Press Stop to send the emergency stop, or Cancel to close the dialog. There is no path that fires E-STOP without this confirmation.

  • The app sends the emergency stop on a dedicated channel, ahead of anything already queued, and repeats it on the reliable command channel.
  • You do not need to own the robot first: the robot accepts E-STOP from any connected device, bypassing the ownership check. It does not take ownership — the current owner stays the same.
  • If the robot does not acknowledge the command, the app logs E-Stop send failed — no response. Use the physical E-Stop. Do not wait — use the physical button.

Physical emergency stop button ​

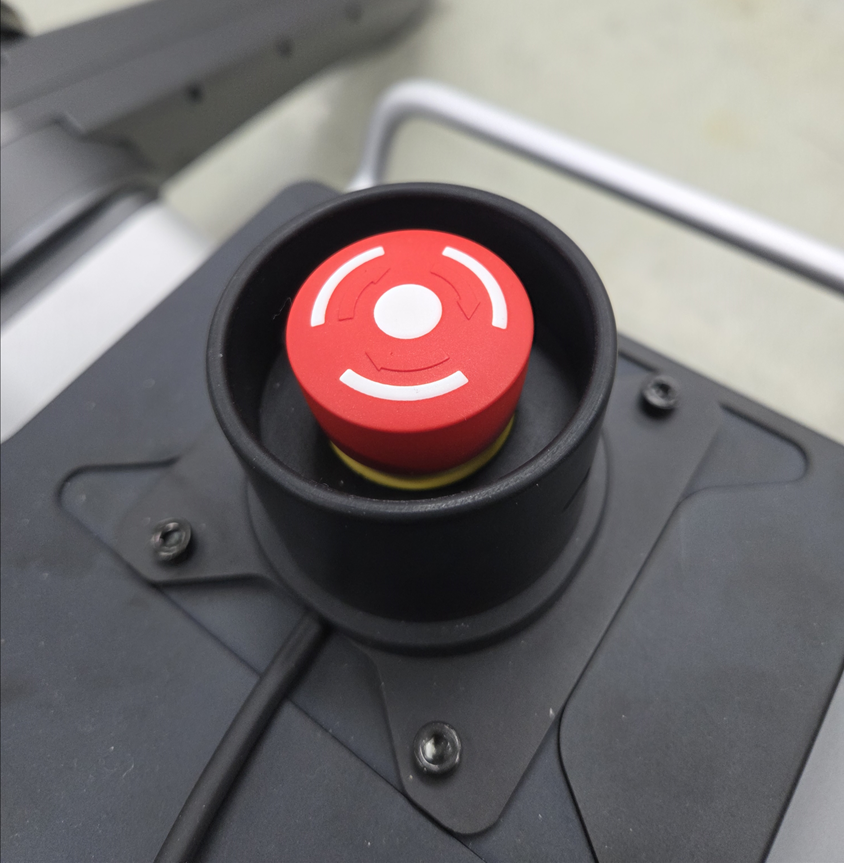
Emergency stop button on the rear of the robot
[ Emergency stop push button — located on the rear of the robot ]

When the physical emergency stop button is pressed, or the app's E-STOP is confirmed:

  • All joints switch to High Damping mode.
  • The robot resists external motion but does not accept torque or position commands.
  • The robot may lose its posture and settle to the ground under gravity.

High Damping mode protects both the user and the robot. The robot will not execute any motion commands until the emergency stop is cleared and the robot is re-initialized.

Recovery ​

  1. Ensure safety — confirm that all people and animals are at least 2 m from the robot.
  2. Release the button — if the physical button was pressed, rotate it clockwise to unlock it.
  3. Return to initial pose — if the robot has fallen or shifted, place it in the initial pose on a flat surface. Do not force the joints while the robot is in High Damping mode.
  4. Re-initialize — run the automatic start sequence or the Stand motion from the control home and confirm the robot state in the top bar before resuming operation.

What developer mode adds here is collected on Developer mode.

Another controller is in control ​

Only one client controls the robot at a time. If you are connected while another app or controller holds ownership, the app dims the whole screen after about a second and blocks every control behind the overlay 다른 컨트롤러가 제어 중입니다 (another controller is in control — this overlay is shown in Korean in both languages):

보기 전용 — 조작하려면 제어권을 가져오세요 (상대 기기는 보기 전용이 됩니다) (View only — take control to operate; the other device becomes view-only.)

A device that is not the owner gets no video, though the status readouts stay visible. The overlay offers:

  • 제어권 가져오기 (take control) — asks the robot to hand ownership to this device. The other device becomes view-only, and the overlay disappears once ownership is yours.
  • ▶ 자동 기동 — after the confirmation Run Auto Start? → Auto Start, takes control and runs the automatic start sequence.
  • E-STOP — after the confirmation Trigger emergency stop? → Run E-STOP, sends the emergency stop without taking control.

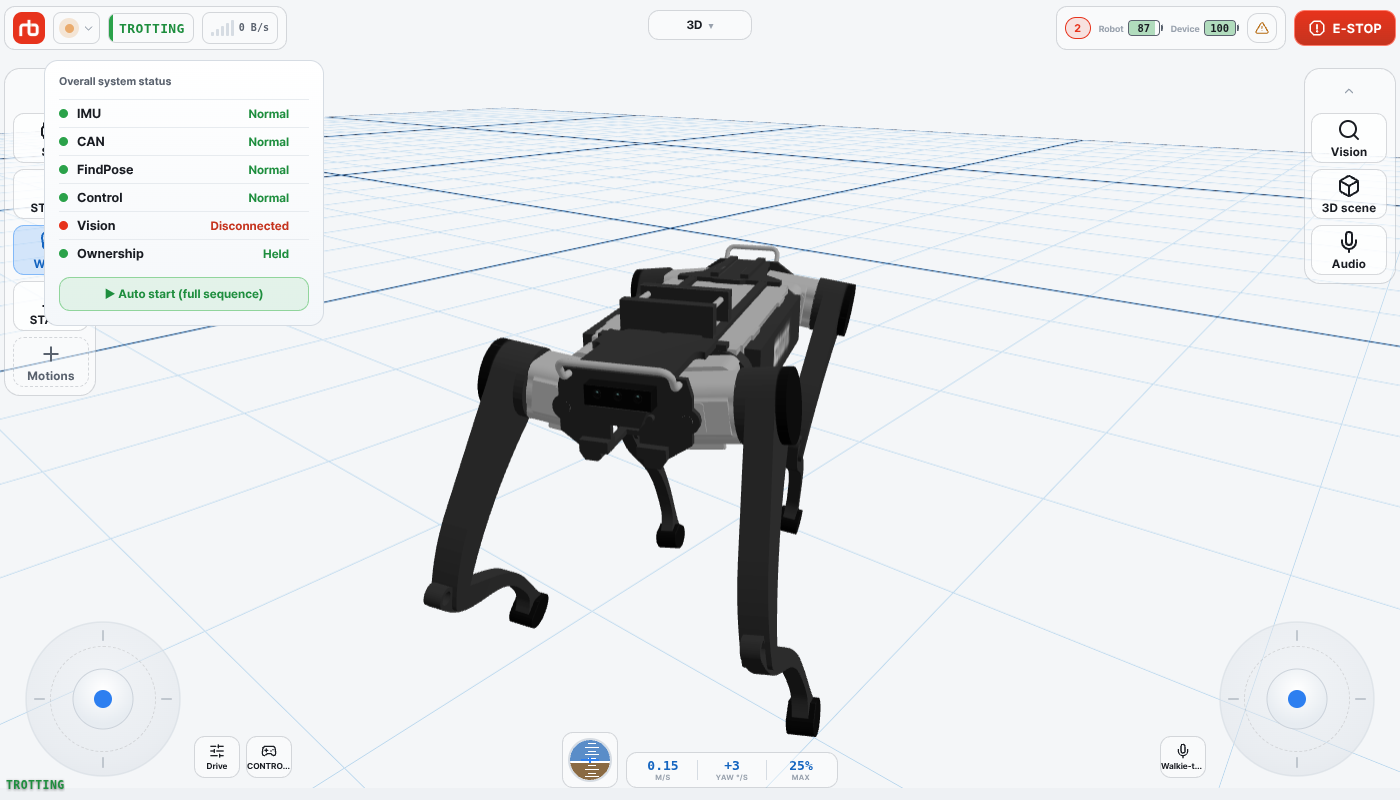
On the control home you can also check and take ownership from the Overall system status popover (tap the status chip in the top bar): the Ownership row shows Held when this device is the owner and Take ▸ when it is not.

Overall system status popover with the Ownership row

This user manual is intended for RBQ users.